Uksang Yoo (유욱상)

Postdoctoral Researcher at UC Berkeley AUTOLab

prof_pic.jpg

I am a postdoctoral researcher with Prof. Ken Goldberg in the AUTOLab at UC Berkeley. I completed my Ph.D. at Carnegie Mellon University in the Robotics Institute (RI), where I was co-advised by Prof. Jean Oh and Prof. Jeffrey Ichnowski as a member of RI’s BIG lab and Momentum lab. I have also worked as a research scientist intern with the robot learning groups at Bosch AI (Summer 2025) and Meta (Fall 2025).

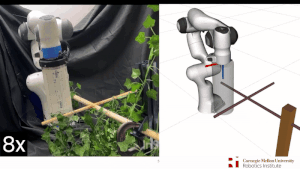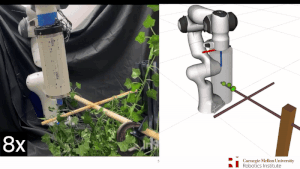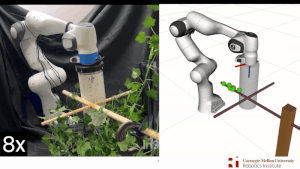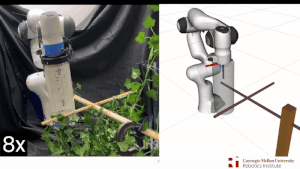
My research investigates how mechanics and physics-based models can enable generalizable learning for dexterous, contact-rich manipulation. In particular, I develop models of contact dynamics and deformation mechanics that provide strong inductive biases for robot learning. My work spans compliant and dexterous manipulation, learning from human demonstrations across embodiments through contact, tactile sensing, and reasoning about the continuous deformation of soft objects/robots during physical interaction.

This research draws on ideas from discrete differential geometry, machine learning, robotics, and soft-body mechanics, with the goal of deploying dexterous robotic systems reliably in the real world.

I received my B.Sc. in Mathematics (2020) and in Mechanical Engineering (2021) at the University of Texas at Austin, where I developed my interest in continuous deformations and continuum structure representation. My research is supported by the NSF Graduate Research Fellowship Program (GRFP).
news

Oct 11, 2026 Our work on SemAnCorr was accepted to IEEE Robotics and Automation Letters (RA-L)! :tada:
Sep 27, 2026 I gave an invited talk, “Why Mechanics Still Matters: Learning and Adaptation for Deformable Manipulation,” at the IROS 2026 Deformable Objects Manipulation workshop!
Jul 2026 I presented SoftAct at Robotics: Science and Systems (RSS) 2026! :tada:
Jul 01, 2026 I started as a postdoctoral researcher in the AUTOLab with Prof. Ken Goldberg at UC Berkeley! :tada:
Jun 10, 2026 I’m co-organizing the RSS Semantic Reasoning and Goal Understanding in Robotics Workshop! :tada:
Jun 02, 2026 I presented our work on DYMO-Hair at ICRA 2026! :tada:
Jun 01, 2026 I gave a talk at the ICRA 2026 CR2 workshop!
May 10, 2026 Our work on A-SLIP was accepted to IROS 2026! :tada:
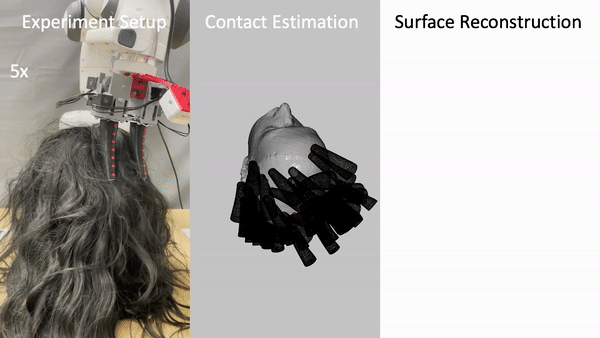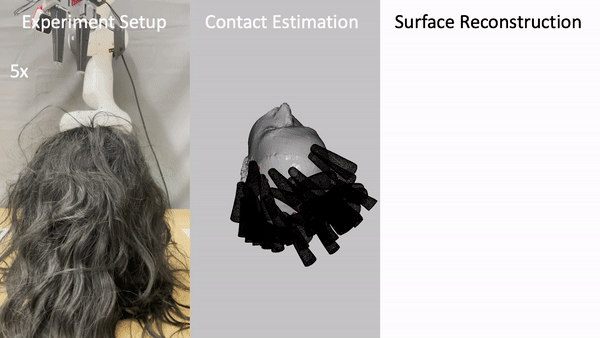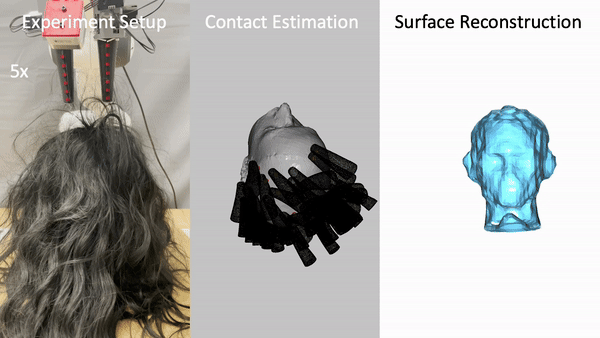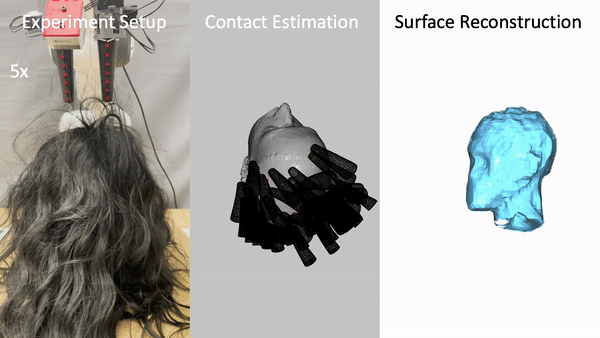
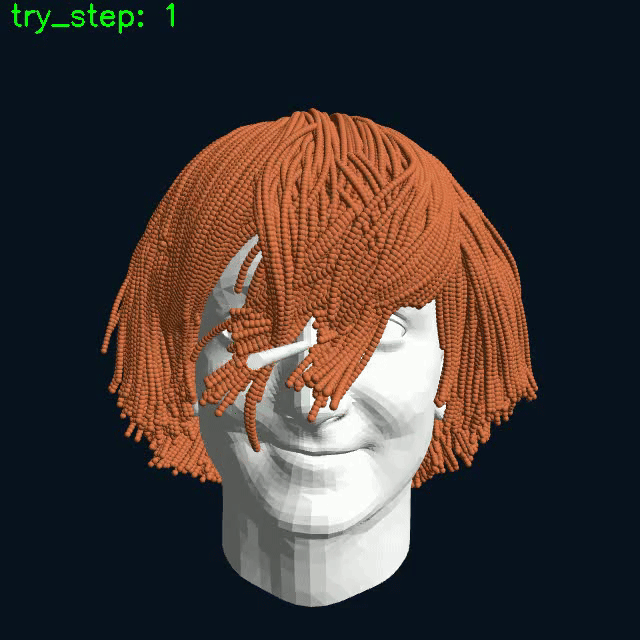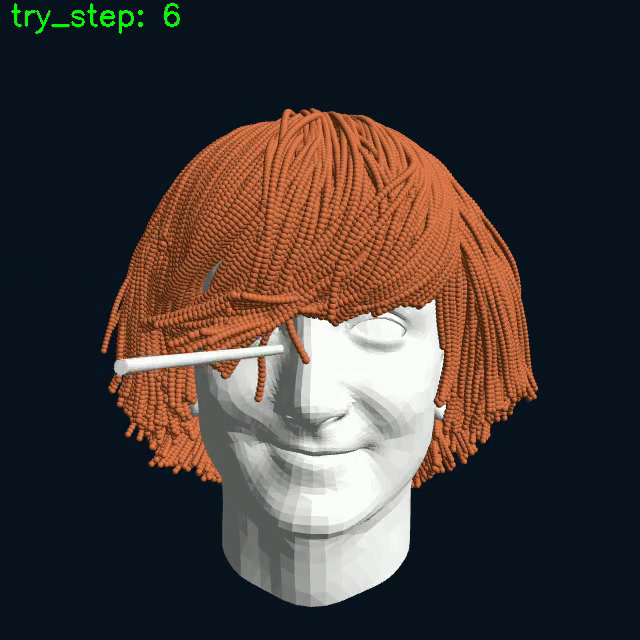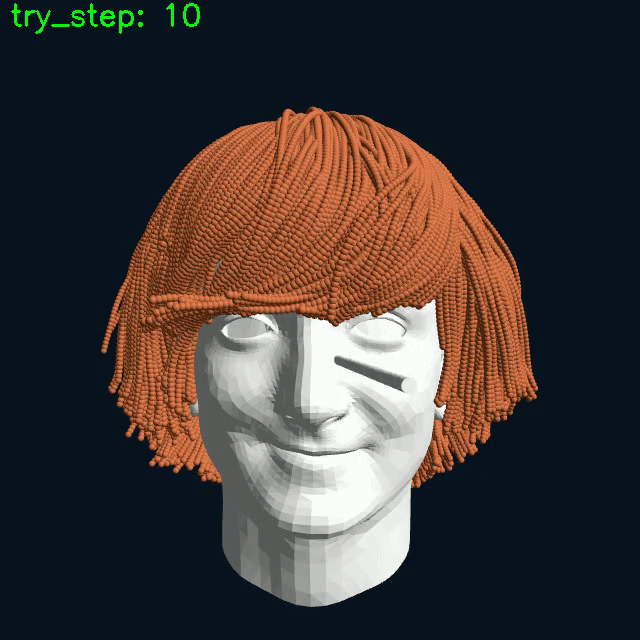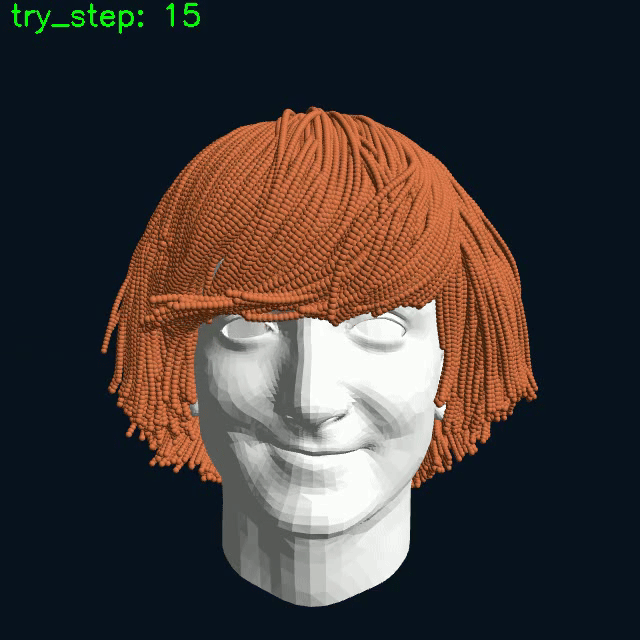
Jan 31, 2026 Our paper on learning dynamics for robot-hair interactions was accepted to ICRA 2026! :tada:
Jan 15, 2026 Our workshop on Real2Sim2Real was accepted to ICRA 2026! We look forward to your submissions :tada:

publications

All papers from 2024 onward.

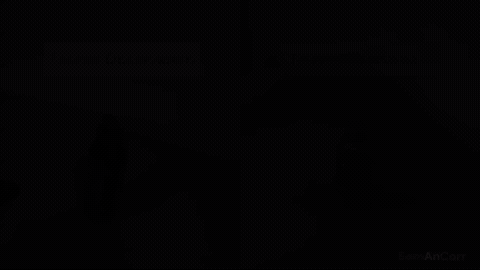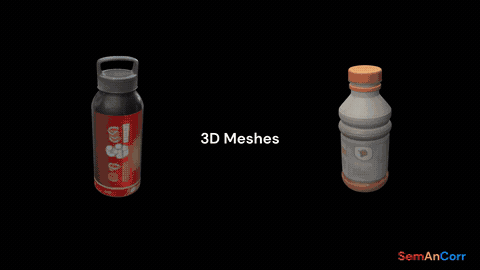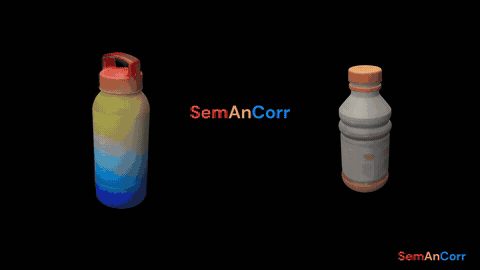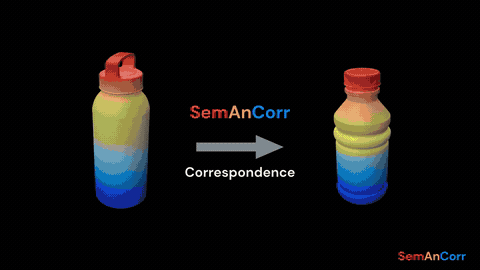
  1. SemAnCorr: Semantic Anchored Correspondence for Zero-Shot Manipulation Skill Transfer
    SemAnCorr: Semantic Anchored Correspondence for Zero-Shot Manipulation Skill Transfer
    Xiaoxiang Dong ,  William Baron ,  Hongyi Chen ,  Uksang Yoo ,  Jeffrey Ichnowski ,  and  Weiming Zhi
    IEEE Robotics and Automation Letters (RA-L), 2026
  2. GaP: A Graph-as-Policy Multi-Agent Self-Learning Harness For Variational Automation Tasks
    GaP: A Graph-as-Policy Multi-Agent Self-Learning Harness For Variational Automation Tasks
    Kaiyuan Chen ,  Shuangyu Xie ,  Letian Fu ,  Justin Yu ,  William Pacini ,  Sandeep Bajamahal ,  Hudson Kim ,  Jaimyn Drake ,  Daehwa Kim ,  Haoru Xue ,  Jonathan Francis ,  Christian Juette ,  Peter Schaldenbrand ,  Muhammet Yunus Seker ,  Ruwan Wickramarachchi ,  Uksang Yoo ,  Guanzhi Wang ,  Adithyavairavan Murali ,  Balakumar Sundaralingam ,  S. Shankar Sastry ,  Spencer Huang ,  Yuke Zhu ,  Linxi "Jim" Fan ,  and  Ken Goldberg
    arXiv preprint arXiv:2607.05369, 2026
  3. VibeAct: Vibration to Actions for Contact-Rich Reactive Robot Dexterity
    VibeAct: Vibration to Actions for Contact-Rich Reactive Robot Dexterity
    Yuemin Mao* ,  Uksang Yoo* ,  Jean Oh ,  Jonathan Francis ,  and  Jeffrey Ichnowski
    arXiv preprint arXiv:2606.27344, 2026
    Tactile Sensing
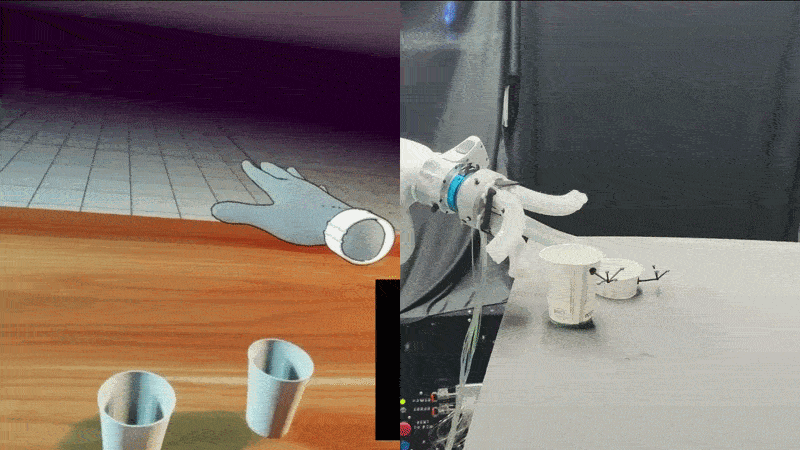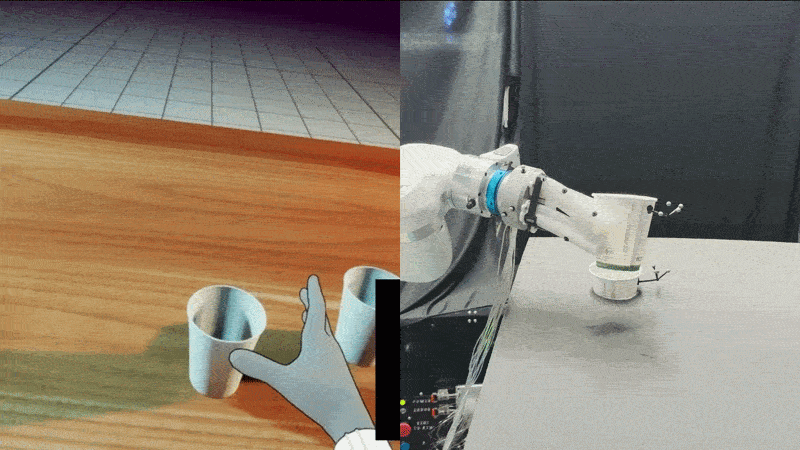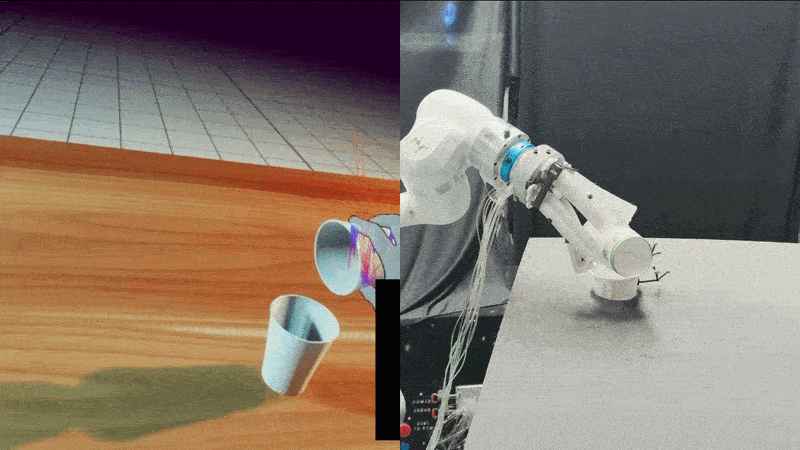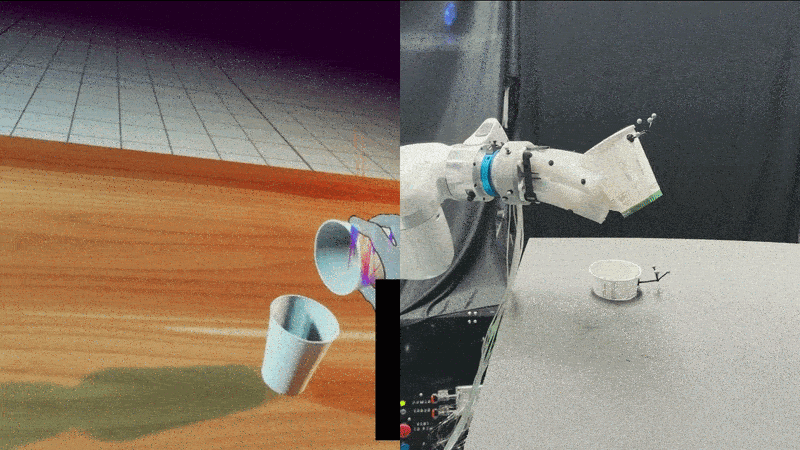
  4. Functional Force-Aware Retargeting from Virtual Human Demos to Soft Robot Policies
    Functional Force-Aware Retargeting from Virtual Human Demos to Soft Robot Policies
    Uksang Yoo ,  Mengjia Zhu ,  Evan Pezent ,  Jom Preechayasomboon ,  Jean Oh ,  Jeffrey Ichnowski ,  Amir Memar ,  Ben Abbatematteo ,  Homanga Bharadhwaj ,  Ashish Deshpande ,  and  Harsha Prahlad
    In Proceedings of Robotics: Science and Systems (RSS) , 2026
    Soft Robots
  5. SOFTMAP: Sim2Real Soft Robot Forward Modeling via Topological Mesh Alignment and Physics Prior
    SOFTMAP: Sim2Real Soft Robot Forward Modeling via Topological Mesh Alignment and Physics Prior
    Ziyong Ma ,  Uksang Yoo ,  Jonathan Francis ,  Weiming Zhi ,  Jeffrey Ichnowski ,  and  Jean Oh
    In 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) , 2026
    Soft Robots
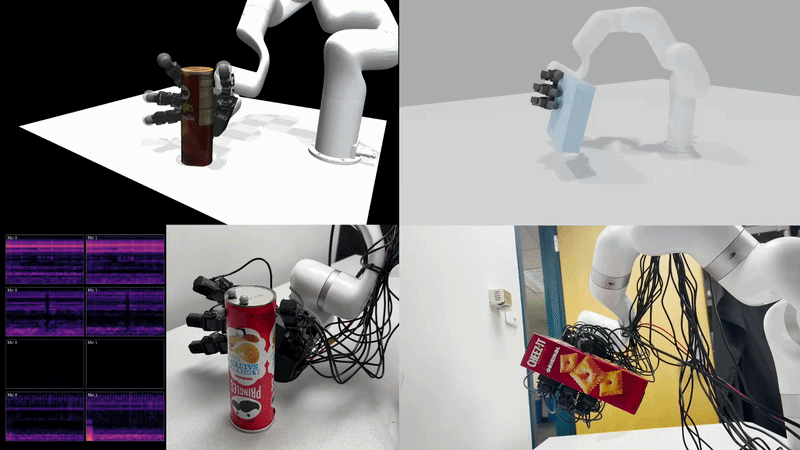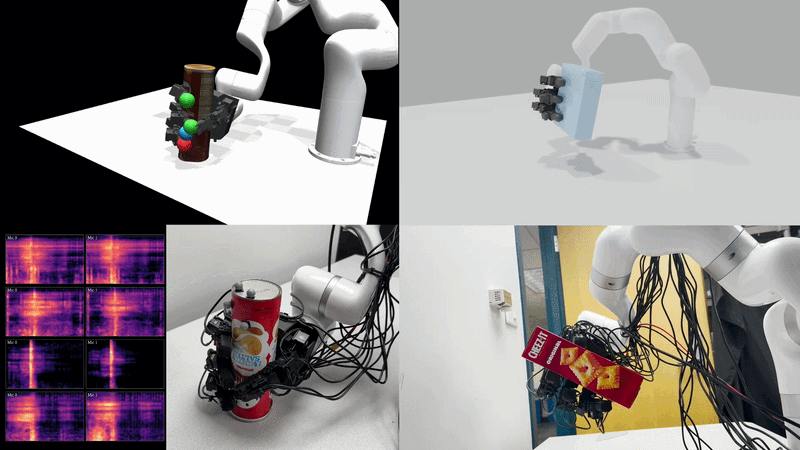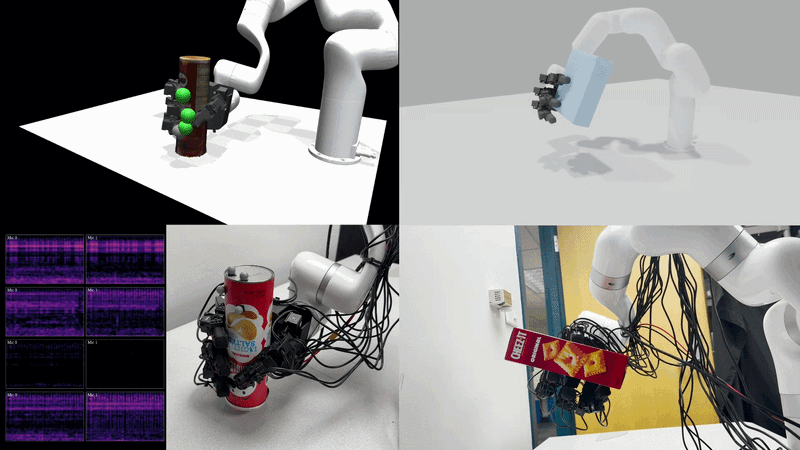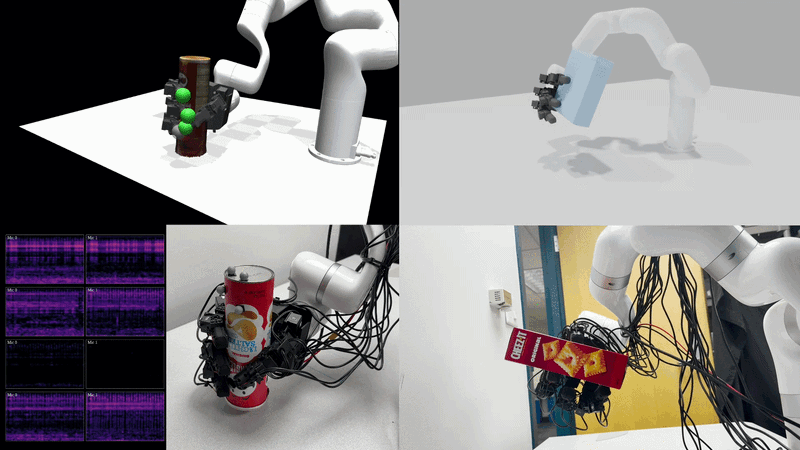
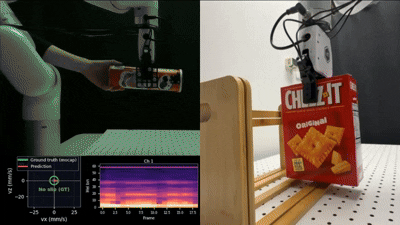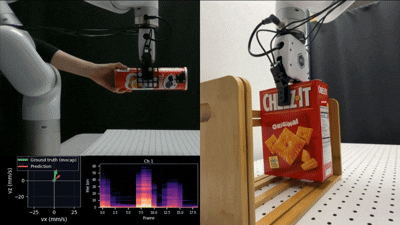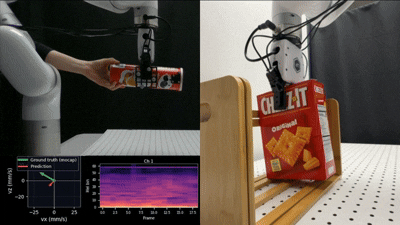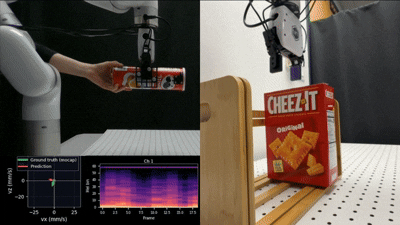
  6. A-SLIP: Acoustic Sensing for Continuous In-hand Slip Estimation
    A-SLIP: Acoustic Sensing for Continuous In-hand Slip Estimation
    Uksang Yoo* ,  Yuemin Mao* ,  Jean Oh ,  and  Jeffrey Ichnowski
    In 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) , 2026
    Tactile Sensing
  7. DYMO-Hair: Generalizable Volumetric Dynamics Modeling for Robot Hair Manipulation
    DYMO-Hair: Generalizable Volumetric Dynamics Modeling for Robot Hair Manipulation
    Chengyang Zhao ,  Uksang Yoo ,  Arkadeep Narayan Chaudhury ,  Giljoo Nam ,  Jonathan Francis ,  Jeffrey Ichnowski ,  and  Jean Oh
    In 2026 IEEE International Conference on Robotics and Automation (ICRA) , 2026
    Deformable Manipulation
  8. KineSoft: Learning Proprioceptive Manipulation Policies with Soft Robot Hands
    KineSoft: Learning Proprioceptive Manipulation Policies with Soft Robot Hands
    Uksang Yoo ,  Jonathan Francis ,  Jean Oh ,  and  Jeffrey Ichnowski
    In Conference on Robot Learning (CoRL) , 2025
    [Oral]
    Soft Robots Award
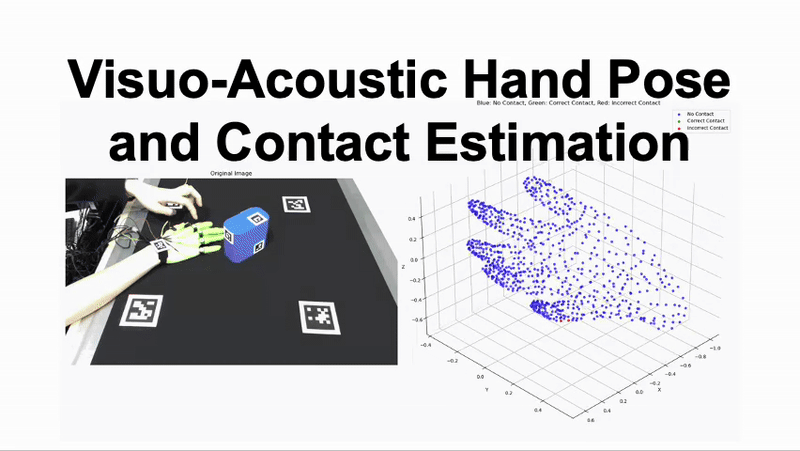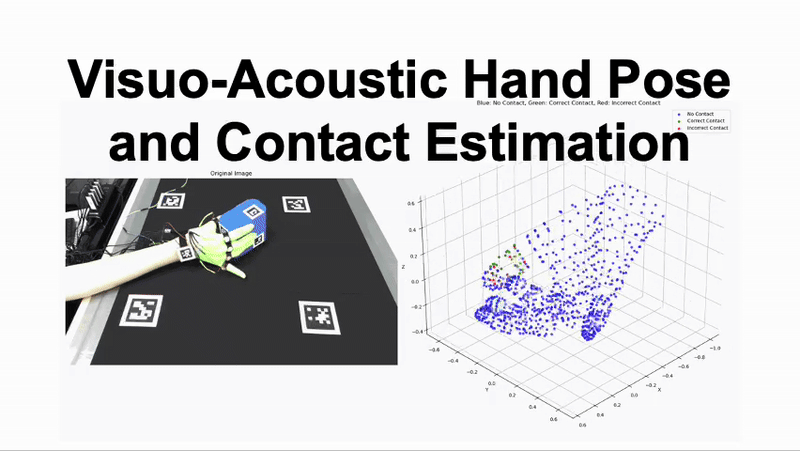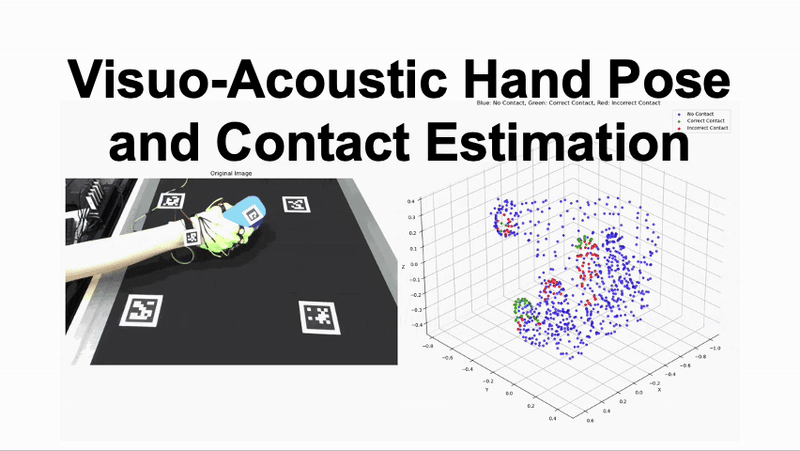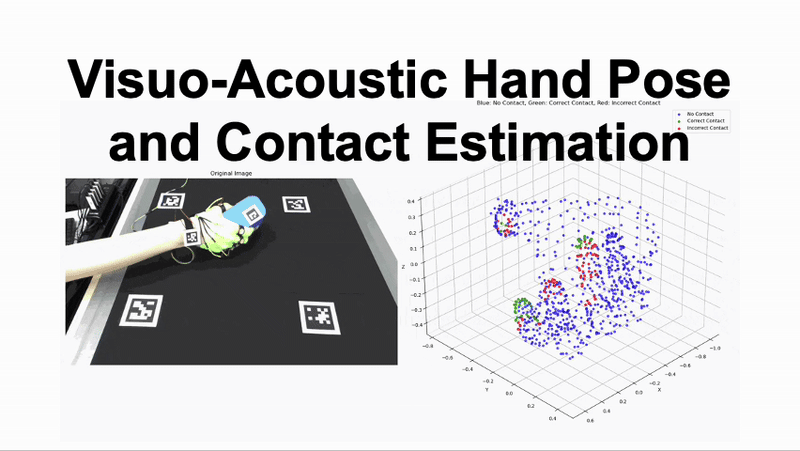
  9. Visuo-Acoustic Hand Pose and Contact Estimation
    Visuo-Acoustic Hand Pose and Contact Estimation
    Yuemin Mao* ,  Uksang Yoo* ,  Yunchao Yao ,  Shahram Najam Syed ,  Luca Bondi ,  Jonathan Francis ,  Jean Oh ,  and  Jeffrey Ichnowski
    In arXiv , 2025
    Tactile Sensing
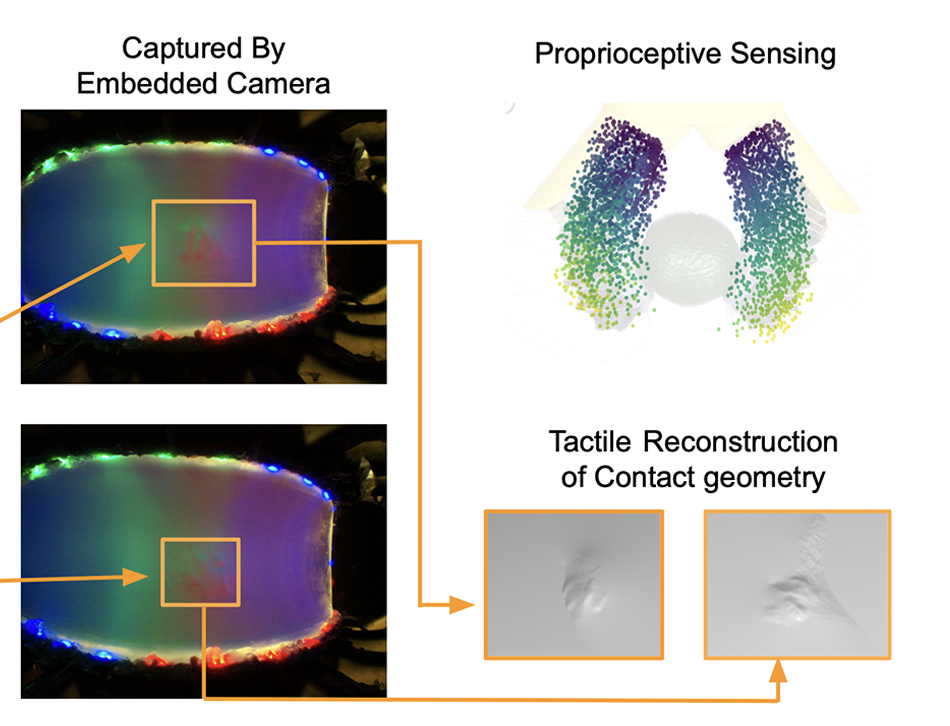
  10. PneuGelSight: Soft Robotic Vision-Based Proprioception and Tactile Sensing
    PneuGelSight: Soft Robotic Vision-Based Proprioception and Tactile Sensing
    Ruohan Zhang ,  Uksang Yoo ,  Yichen Li ,  Arpit Argawal ,  and  Wenzhen Yuan
    In International Journal on Robotics Research (IJRR) , 2025
    Soft Robots Tactile Sensing
  11. Soft and Compliant Contact-Rich Hair Manipulation and Care
    Soft and Compliant Contact-Rich Hair Manipulation and Care
    Uksang Yoo ,  Nathaniel Dennler ,  Eliot Xing ,  Maja Mataric ,  Stefanos Nikolaidis ,  Jeffrey Ichnowski ,  and  Jean Oh
    In International Conference on Human-Robot Interaction (HRI) , 2025
    [Best Paper Finalist]
    Soft Robots Tactile Sensing Deformable Manipulation Award
  12. SonicBoom: Contact Localization Using Array of Microphones
    SonicBoom: Contact Localization Using Array of Microphones
    Moonyoung Lee ,  Uksang Yoo ,  Jean Oh ,  Jeffrey Ichnowski ,  George Kantor ,  and  Oliver Kroemer
    In IEEE robotics and automation letters , 2025
    Tactile Sensing
  13. Soft Robotic Dynamic In-Hand Pen Spinning
    Soft Robotic Dynamic In-Hand Pen Spinning
    Yunchao Yao ,  Uksang Yoo ,  Jean Oh ,  Christopher G. Atkeson ,  and  Jeffrey Ichnowski
    In 2025 IEEE International Conference on Robotics and Automation (ICRA) , 2025
    Soft Robots
  14. SoftBiT: Soft Bimanual Teleoperation with Proprioceptive Visual Augmentation
    Tai Inui ,  Uksang Yoo ,  Jeffrey Ichnowski ,  and  Jean Oh
    In HRI Workshop on Virtual, Augmented, and Mixed Reality for Human-Robot Interaction (VAM-HRI) , 2025
    Soft Robots
  15. Modeling Personalized Difficulty of Rehabilitation Exercises Using Causal Trees
    Modeling Personalized Difficulty of Rehabilitation Exercises Using Causal Trees
    Nathaniel Dennler ,  Zhonghao Shi ,  Uksang Yoo ,  Stefanos Nikolaidis ,  and  Maja Mataric
    In IEEE/RAS-EMBS International Conference on Rehabilitation Robotics (ICORR) , 2025
  16. PyLips: an Open-Source Python Package to Expand Participation in Embodied Interaction
    PyLips: an Open-Source Python Package to Expand Participation in Embodied Interaction
    Nathaniel Steele Dennler ,  Evan Torrence ,  Uksang Yoo ,  Stefanos Nikolaidis ,  and  Maja Mataric
    In Adjunct Proceedings of the 37th Annual ACM Symposium on User Interface Software and Technology (UIST) , 2024
    Soft Robots
  17. RoPotter: Toward Robotic Pottery and Deformable Object Manipulation with Structural Priors
    RoPotter: Toward Robotic Pottery and Deformable Object Manipulation with Structural Priors
    Uksang Yoo* ,  Adam Hung* ,  Jonathan Francis ,  Jean Oh ,  and  Jeffrey Ichnowski
    In 2024 IEEE International Conference on Humanoid Robots (Humanoids) , 2024
    [Best Oral Paper Finalist]
    Deformable Manipulation Award
  18. MOE-Touch More Deformation: Shape-Based Soft Robotic Contact Estimation for Manipulation
    MOE-Touch More Deformation: Shape-Based Soft Robotic Contact Estimation for Manipulation
    Uksang Yoo ,  Sarvesh Patil ,  Eliot Xing ,  Zeynep Temel ,  Oliver Kroemer ,  Jeffrey Ichnowski ,  and  Jean Oh
    In [Under Review] , 2024
    Soft Robots Tactile Sensing Deformable Manipulation
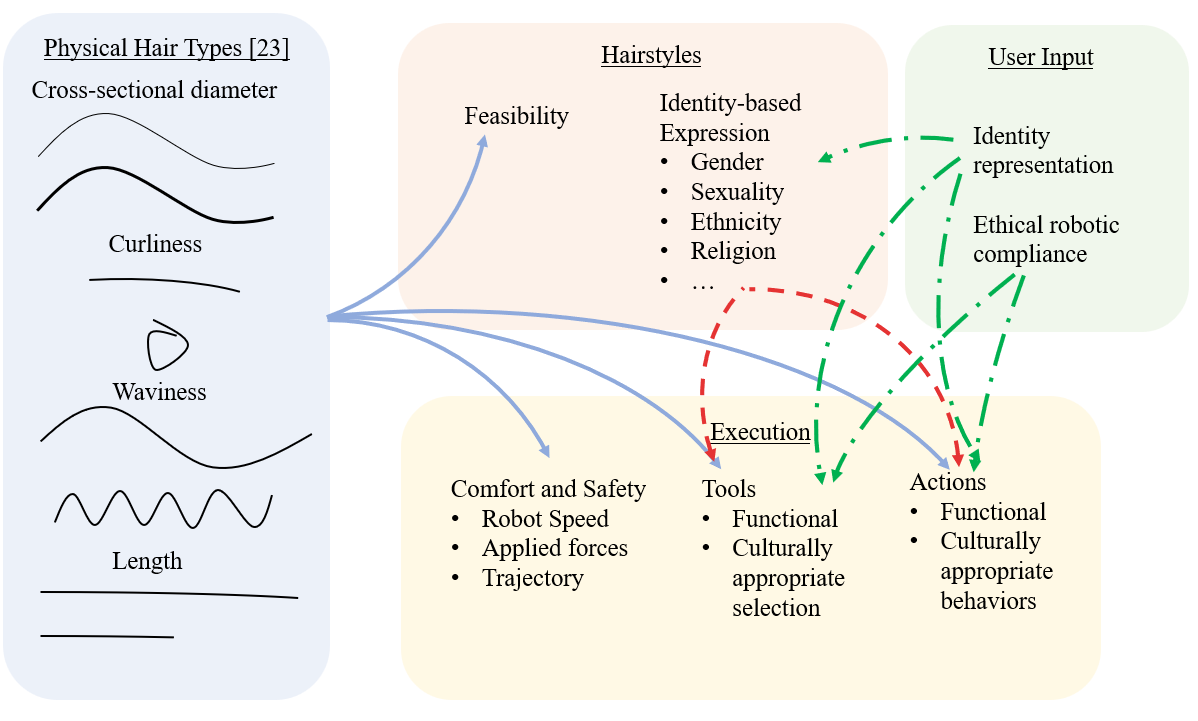
  19. Inclusion in Assistive Haircare Robotics: Practical and Ethical Considerations in Hair Manipulation
    Inclusion in Assistive Haircare Robotics: Practical and Ethical Considerations in Hair Manipulation
    Uksang Yoo ,  Nathaniel Dennler ,  Sarvesh Patil ,  Jean Oh ,  and  Jeffrey Ichnowski
    In Third Workshop on Inclusive HRI , 2024
    Deformable Manipulation
  20. MOE-Hair: Toward Soft and Compliant Contact-rich Hair Manipulation and Care [Best LBR at HRI 2024]
    MOE-Hair: Toward Soft and Compliant Contact-rich Hair Manipulation and Care [Best LBR at HRI 2024]
    Uksang Yoo ,  Nathaniel Dennler ,  Maja Mataric ,  Stefanos Nikolaidis ,  Jean Oh ,  and  Jeffrey Ichnowski
    In Late Breaking Report, International Conference on Human-Robot Interaction (HRI) , 2024
    [Best LBR]
    Soft Robots Tactile Sensing Deformable Manipulation Award
  21. POE: Acoustic Soft Robotic Proprioception for Omnidirectional End-effectors
    POE: Acoustic Soft Robotic Proprioception for Omnidirectional End-effectors
    Uksang Yoo ,  Ziven Lopez ,  Jeffrey Ichnowski ,  and  Jean Oh
    In 2024 IEEE International Conference on Robotics and Automation (ICRA) , 2024
    Soft Robots Tactile Sensing

Full publication archive →