publications

Full publication archive, including journal articles, conference papers, preprints, and workshop papers.

2026
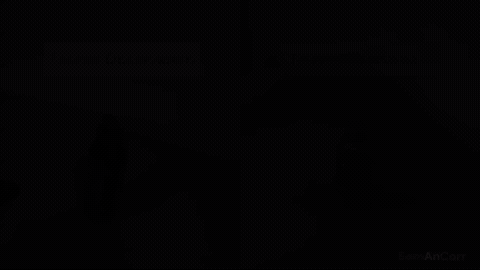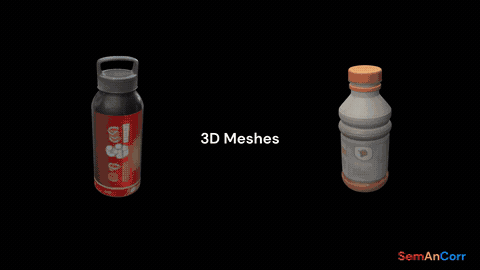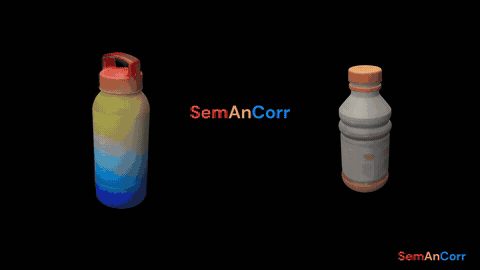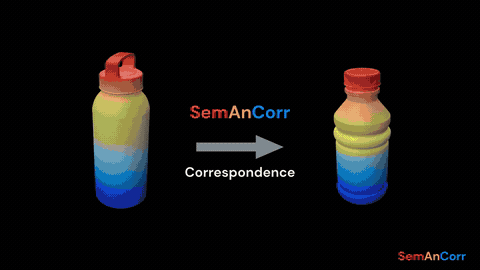
  1. SemAnCorr: Semantic Anchored Correspondence for Zero-Shot Manipulation Skill Transfer
    SemAnCorr: Semantic Anchored Correspondence for Zero-Shot Manipulation Skill Transfer
    Xiaoxiang Dong ,  William Baron ,  Hongyi Chen ,  Uksang Yoo ,  Jeffrey Ichnowski ,  and  Weiming Zhi
    IEEE Robotics and Automation Letters (RA-L), 2026
  2. GaP: A Graph-as-Policy Multi-Agent Self-Learning Harness For Variational Automation Tasks
    GaP: A Graph-as-Policy Multi-Agent Self-Learning Harness For Variational Automation Tasks
    Kaiyuan Chen ,  Shuangyu Xie ,  Letian Fu ,  Justin Yu ,  William Pacini ,  Sandeep Bajamahal ,  Hudson Kim ,  Jaimyn Drake ,  Daehwa Kim ,  Haoru Xue ,  Jonathan Francis ,  Christian Juette ,  Peter Schaldenbrand ,  Muhammet Yunus Seker ,  Ruwan Wickramarachchi ,  Uksang Yoo ,  Guanzhi Wang ,  Adithyavairavan Murali ,  Balakumar Sundaralingam ,  S. Shankar Sastry ,  Spencer Huang ,  Yuke Zhu ,  Linxi "Jim" Fan ,  and  Ken Goldberg
    arXiv preprint arXiv:2607.05369, 2026
  3. VibeAct: Vibration to Actions for Contact-Rich Reactive Robot Dexterity
    VibeAct: Vibration to Actions for Contact-Rich Reactive Robot Dexterity
    Yuemin Mao* ,  Uksang Yoo* ,  Jean Oh ,  Jonathan Francis ,  and  Jeffrey Ichnowski
    arXiv preprint arXiv:2606.27344, 2026
    Tactile Sensing
  4. Functional Force-Aware Retargeting from Virtual Human Demos to Soft Robot Policies
    Functional Force-Aware Retargeting from Virtual Human Demos to Soft Robot Policies
    Uksang Yoo ,  Mengjia Zhu ,  Evan Pezent ,  Jom Preechayasomboon ,  Jean Oh ,  Jeffrey Ichnowski ,  Amir Memar ,  Ben Abbatematteo ,  Homanga Bharadhwaj ,  Ashish Deshpande ,  and  Harsha Prahlad
    In Proceedings of Robotics: Science and Systems (RSS) , 2026
    Soft Robots
  5. SOFTMAP: Sim2Real Soft Robot Forward Modeling via Topological Mesh Alignment and Physics Prior
    SOFTMAP: Sim2Real Soft Robot Forward Modeling via Topological Mesh Alignment and Physics Prior
    Ziyong Ma ,  Uksang Yoo ,  Jonathan Francis ,  Weiming Zhi ,  Jeffrey Ichnowski ,  and  Jean Oh
    In 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) , 2026
    Soft Robots
  6. A-SLIP: Acoustic Sensing for Continuous In-hand Slip Estimation
    A-SLIP: Acoustic Sensing for Continuous In-hand Slip Estimation
    Uksang Yoo* ,  Yuemin Mao* ,  Jean Oh ,  and  Jeffrey Ichnowski
    In 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) , 2026
    Tactile Sensing
  7. DYMO-Hair: Generalizable Volumetric Dynamics Modeling for Robot Hair Manipulation
    DYMO-Hair: Generalizable Volumetric Dynamics Modeling for Robot Hair Manipulation
    Chengyang Zhao ,  Uksang Yoo ,  Arkadeep Narayan Chaudhury ,  Giljoo Nam ,  Jonathan Francis ,  Jeffrey Ichnowski ,  and  Jean Oh
    In 2026 IEEE International Conference on Robotics and Automation (ICRA) , 2026
    Deformable Manipulation

2025

  1. KineSoft: Learning Proprioceptive Manipulation Policies with Soft Robot Hands
    KineSoft: Learning Proprioceptive Manipulation Policies with Soft Robot Hands
    Uksang Yoo ,  Jonathan Francis ,  Jean Oh ,  and  Jeffrey Ichnowski
    In Conference on Robot Learning (CoRL) , 2025
    [Oral]
    Soft Robots Award
  2. Visuo-Acoustic Hand Pose and Contact Estimation
    Visuo-Acoustic Hand Pose and Contact Estimation
    Yuemin Mao* ,  Uksang Yoo* ,  Yunchao Yao ,  Shahram Najam Syed ,  Luca Bondi ,  Jonathan Francis ,  Jean Oh ,  and  Jeffrey Ichnowski
    In arXiv , 2025
    Tactile Sensing
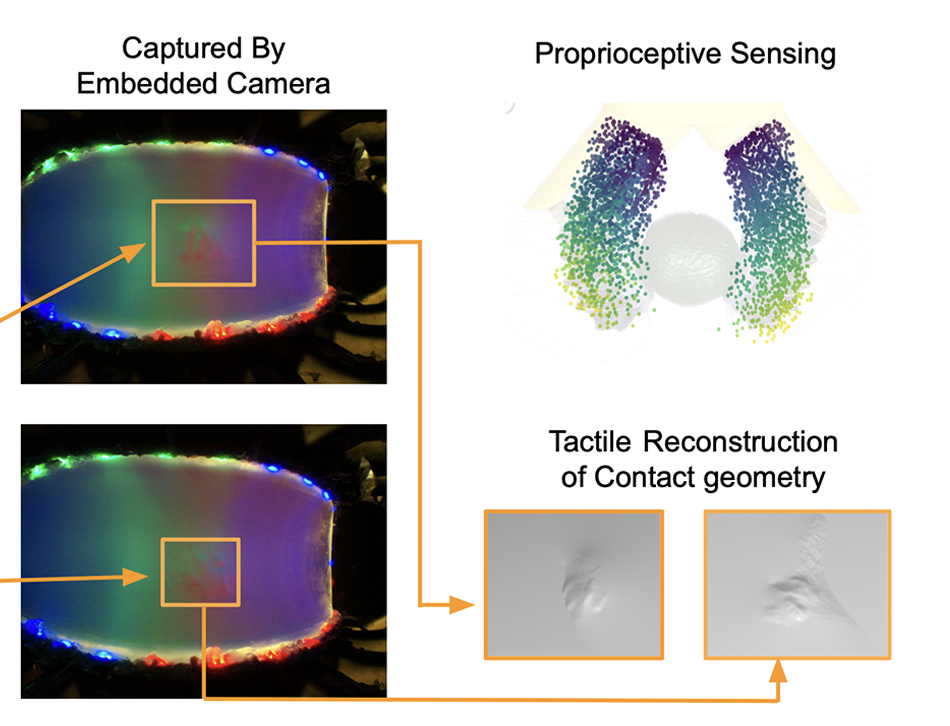
  3. PneuGelSight: Soft Robotic Vision-Based Proprioception and Tactile Sensing
    PneuGelSight: Soft Robotic Vision-Based Proprioception and Tactile Sensing
    Ruohan Zhang ,  Uksang Yoo ,  Yichen Li ,  Arpit Argawal ,  and  Wenzhen Yuan
    In International Journal on Robotics Research (IJRR) , 2025
    Soft Robots Tactile Sensing
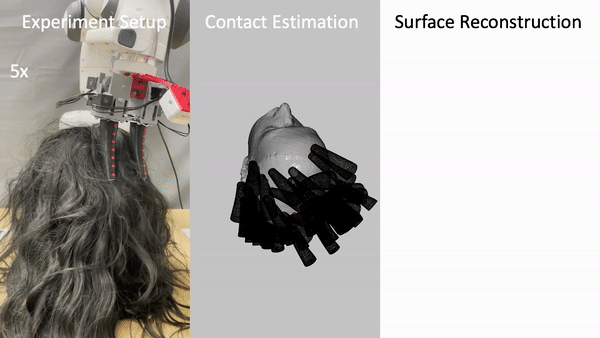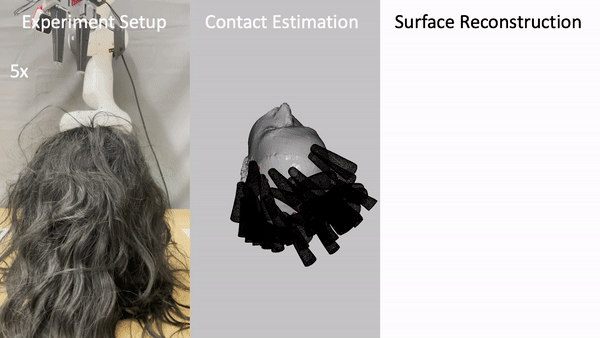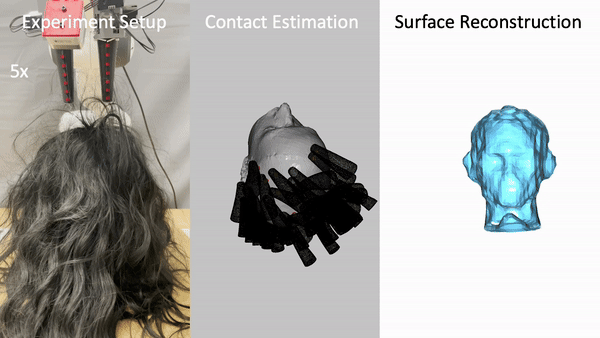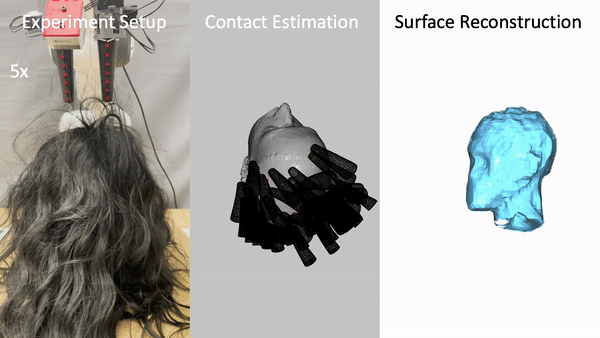
  4. Soft and Compliant Contact-Rich Hair Manipulation and Care
    Soft and Compliant Contact-Rich Hair Manipulation and Care
    Uksang Yoo ,  Nathaniel Dennler ,  Eliot Xing ,  Maja Mataric ,  Stefanos Nikolaidis ,  Jeffrey Ichnowski ,  and  Jean Oh
    In International Conference on Human-Robot Interaction (HRI) , 2025
    [Best Paper Finalist]
    Soft Robots Tactile Sensing Deformable Manipulation Award
  5. SonicBoom: Contact Localization Using Array of Microphones
    SonicBoom: Contact Localization Using Array of Microphones
    Moonyoung Lee ,  Uksang Yoo ,  Jean Oh ,  Jeffrey Ichnowski ,  George Kantor ,  and  Oliver Kroemer
    In IEEE robotics and automation letters , 2025
    Tactile Sensing
  6. Soft Robotic Dynamic In-Hand Pen Spinning
    Soft Robotic Dynamic In-Hand Pen Spinning
    Yunchao Yao ,  Uksang Yoo ,  Jean Oh ,  Christopher G. Atkeson ,  and  Jeffrey Ichnowski
    In 2025 IEEE International Conference on Robotics and Automation (ICRA) , 2025
    Soft Robots
  7. SoftBiT: Soft Bimanual Teleoperation with Proprioceptive Visual Augmentation
    Tai Inui ,  Uksang Yoo ,  Jeffrey Ichnowski ,  and  Jean Oh
    In HRI Workshop on Virtual, Augmented, and Mixed Reality for Human-Robot Interaction (VAM-HRI) , 2025
    Soft Robots
  8. Modeling Personalized Difficulty of Rehabilitation Exercises Using Causal Trees
    Modeling Personalized Difficulty of Rehabilitation Exercises Using Causal Trees
    Nathaniel Dennler ,  Zhonghao Shi ,  Uksang Yoo ,  Stefanos Nikolaidis ,  and  Maja Mataric
    In IEEE/RAS-EMBS International Conference on Rehabilitation Robotics (ICORR) , 2025

2024

  1. PyLips: an Open-Source Python Package to Expand Participation in Embodied Interaction
    PyLips: an Open-Source Python Package to Expand Participation in Embodied Interaction
    Nathaniel Steele Dennler ,  Evan Torrence ,  Uksang Yoo ,  Stefanos Nikolaidis ,  and  Maja Mataric
    In Adjunct Proceedings of the 37th Annual ACM Symposium on User Interface Software and Technology (UIST) , 2024
    Soft Robots
  2. RoPotter: Toward Robotic Pottery and Deformable Object Manipulation with Structural Priors
    RoPotter: Toward Robotic Pottery and Deformable Object Manipulation with Structural Priors
    Uksang Yoo* ,  Adam Hung* ,  Jonathan Francis ,  Jean Oh ,  and  Jeffrey Ichnowski
    In 2024 IEEE International Conference on Humanoid Robots (Humanoids) , 2024
    [Best Oral Paper Finalist]
    Deformable Manipulation Award
  3. MOE-Touch More Deformation: Shape-Based Soft Robotic Contact Estimation for Manipulation
    MOE-Touch More Deformation: Shape-Based Soft Robotic Contact Estimation for Manipulation
    Uksang Yoo ,  Sarvesh Patil ,  Eliot Xing ,  Zeynep Temel ,  Oliver Kroemer ,  Jeffrey Ichnowski ,  and  Jean Oh
    In [Under Review] , 2024
    Soft Robots Tactile Sensing Deformable Manipulation
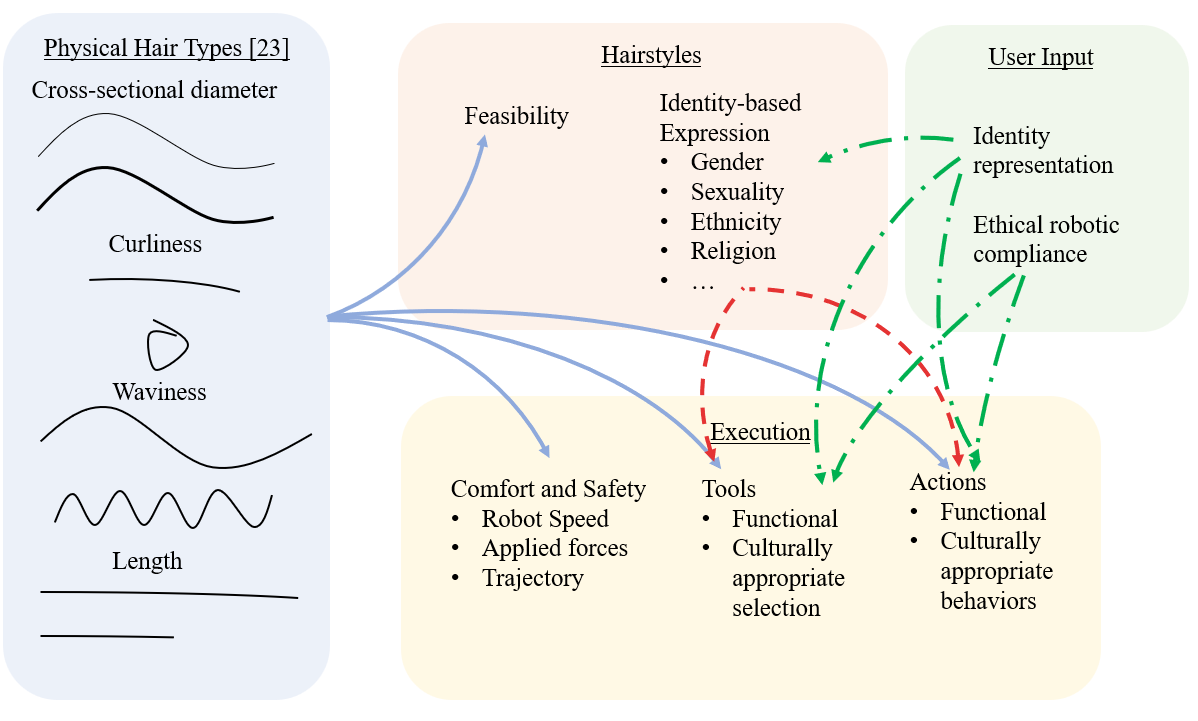
  4. Inclusion in Assistive Haircare Robotics: Practical and Ethical Considerations in Hair Manipulation
    Inclusion in Assistive Haircare Robotics: Practical and Ethical Considerations in Hair Manipulation
    Uksang Yoo ,  Nathaniel Dennler ,  Sarvesh Patil ,  Jean Oh ,  and  Jeffrey Ichnowski
    In Third Workshop on Inclusive HRI , 2024
    Deformable Manipulation
  5. MOE-Hair: Toward Soft and Compliant Contact-rich Hair Manipulation and Care [Best LBR at HRI 2024]
    MOE-Hair: Toward Soft and Compliant Contact-rich Hair Manipulation and Care [Best LBR at HRI 2024]
    Uksang Yoo ,  Nathaniel Dennler ,  Maja Mataric ,  Stefanos Nikolaidis ,  Jean Oh ,  and  Jeffrey Ichnowski
    In Late Breaking Report, International Conference on Human-Robot Interaction (HRI) , 2024
    [Best LBR]
    Soft Robots Tactile Sensing Deformable Manipulation Award
  6. POE: Acoustic Soft Robotic Proprioception for Omnidirectional End-effectors
    POE: Acoustic Soft Robotic Proprioception for Omnidirectional End-effectors
    Uksang Yoo ,  Ziven Lopez ,  Jeffrey Ichnowski ,  and  Jean Oh
    In 2024 IEEE International Conference on Robotics and Automation (ICRA) , 2024
    Soft Robots Tactile Sensing

2023

  1. Toward Zero-Shot Sim-to-Real Transfer Learning for Pneumatic Soft Robot 3D Proprioceptive Sensing
    Toward Zero-Shot Sim-to-Real Transfer Learning for Pneumatic Soft Robot 3D Proprioceptive Sensing
    Uksang Yoo ,  Hanwen Zhao ,  Alvaro Altamirano ,  Wenzhen Yuan ,  and  Chen Feng
    In 2023 IEEE International Conference on Robotics and Automation (ICRA) , 2023
    Soft Robots

2022

  1. Influence of antagonistic tensions on distributed friction forces of multisegment tendon-driven continuum manipulators with irregular geometry
    Influence of antagonistic tensions on distributed friction forces of multisegment tendon-driven continuum manipulators with irregular geometry
    Yang Liu ,  Uksang Yoo ,  Seungbeom Ha ,  S Farokh Atashzar ,  and  Farshid Alambeigi
    IEEE/ASME Transactions on Mechatronics, 2022
  2. In-Hand Pose Estimation with Optical Tactile Sensor for Robotic Electronics Assembly
    In-Hand Pose Estimation with Optical Tactile Sensor for Robotic Electronics Assembly
    Uksang Yoo ,  and  Wenzhen Yuan
    2022
    Tactile Sensing

2021

  1. Analytical Design of a Pneumatic Elastomer Robot With Deterministically Adjusted Stiffness
    Analytical Design of a Pneumatic Elastomer Robot With Deterministically Adjusted Stiffness
    Uksang Yoo ,  Yang Liu ,  Ashish D Deshpande ,  and  Farshid Alamabeigi
    IEEE robotics and automation letters, 2021
    Soft Robots

2020

  1. Toward Analytical Modeling and Evaluation of Curvature-Dependent Distributed Friction Force in Tendon-Driven Continuum Manipulators
    Yang Liu ,  Seong Hyo Ahn ,  Uksang Yoo ,  Alexander R. Cohen ,  and  Farshid Alambeigi
    In 2020 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) , 2020